Comparing Grip Materials to a Cylinder Using a Hydraulic Arm
CSEF · 2019 Applied Mechanics & Structures
Overview
Objectives The objective of this study is to find grips that are affordable and effective so that the cost of prosthetic arms could be lowered while the effectiveness of the prosthetic arm could remain the same or even become more effective. Methods Materials that I used was a Hydraulic arm, 4 different grip materials, and a soda can. These materials helped me measure the effectiveness of different grips based on if the arm was able to hold the soda can or not. Results Grips that were stickier or stretchier were over 50% more effective than the grips that were more silk-like and slippery when holding the can. Several trials were recorded and the averages were the results. The results showed that the stretchier the material, the better. Conclusions In conclusion, multiple trials show that grips that were more stretchy were more likely to be able to hold the can than the grips that were slippery. This shows that my Hypothesis was on the right track and that there were other factors that I did not think about before that I needed to research in order to do the experiment. I have concluded that the grips that I have tested are more effective than those, more expensive material, used for prosthetic arms.
Summary statement
I created a hydraulic arm that would be able to hold a soda can to test different grips that were less than $5 to find which materials were the most effective to help make prosthetic arms more effective and affordable at the same time.
Help received
I designed the hydraulic arm myself, using a few different ideas I found online while I was researching and I also designed some of it myself. I built the whole arm by myself with no help.
Competition history
- CSEF 2019
Resources
Related projects
CYSF · 2026
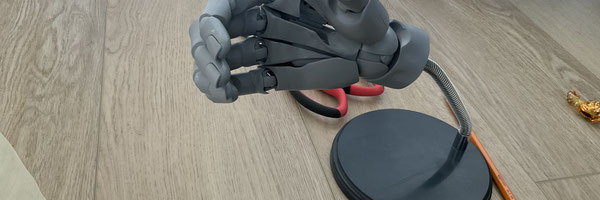
Improving Grip Performance in an Articulating Model of Prosthetic Hand Using Different Materials
CSEF · 2015
Dexterity of a Soft Robotic Gripper
CSEF · 2015
HomeMade Amputee Arm: H.M.A.A.
CSEF · 2016
Grasping the Future: A Fully Functional, Affordable, Electromechanically Controlled Bionic Hand
CSEF · 2013
We're Jammin': Using the Jamming Principle to Construct a Universal Gripper
CSEF · 2015
The Claw Cane; A Cane with a Claw Mechanism for Picking up Dropped Items
CSEF · 2017
Assistive Robotic Mechanism 2
ISEF · 2016
The Iron Hand, Year Four
Closest projects by meaning, across every fair and year in the corpus.
Browse more like this
Source: California Science & Engineering Fair public projects